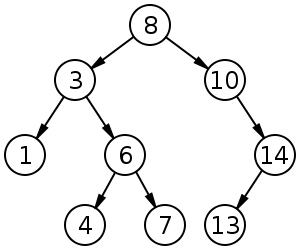
both types of nodes also need a reference to the locally stored value
data fields are item, left,
right
methods include constructors, accessor methods, mutator methods,
toString
test program builds small tree, tests the methods
in-class exercise: build the following tree using the methods
from class BinaryNode
binary nodes can be used for binary search trees, but
also for other kinds of binary trees
Binary search tree add operation
if key is less than the key of the current node, recursively add to
the left subtree
if key is greater than the key of the current node, recursively add to
the right subtree
otherwise, add at this node:
if there is no current node, create one and return it
if there is a current node, replace its contents with the
new contents
this assumes:
the method returns a new root for the new (sub)tree with the
desired value inserted
the caller of this method knows what to do with the new root
in-class exercise: create a new binary tree using as keys the following
letters, in the order given: "hello world". These keys each
carry the value 1, 2, 3, 4, 5, 6, 7 8, 9, 10, 11
Binary search tree delete operation
find node with the given key
if the node is a leaf node, just delete it, return null
if the node only has a left subtree, return the left subtree
if the node only has a right subtree, return the right subtree
if the node has both subtrees, must replace it with another node
that fits in the slot
Removing a node that has both subtrees
the rightmost node in the left subtree can be put in
place of the current node without altering the sorted property
likewise, the leftmost node in the right subtree can be put in
place of the current node
that node might have a left (right) subtree, which can
be used in its old position
the rightmost node in the left subtree is the inorder predecessor
of the current node
the leftmost node in the right subtree is the inorder successor
of the current node
so either can be used
in-class exercise: delete node 17 from this tree:
in-class exercise (individually): delete node 14 from the original tree
in-class exercise (individually): delete node 31 from the original tree
binary tree traversal
binary tree traversal is easy using recursion:
preorder: visit the root node, then recursively visit the left
subtree, then recursively visit the right subtree
inorder: recursively visit the left subtree, then visit the root node,
then recursively visit the right subtree
postorder: recursively visit the left subtree
then recursively visit the right subtree, then visit the root node
this is hard using just loops
a stack is needed to keep track of where we are in the tree
for example, for preorder traversal, I would visit (print, etc) the
current node, push onto the stack the right subtree, then visit the
left subtree
when I reach a leaf node, I pop the next subtree off the stack, and
continue from that node
inorder and postorder are more complex
this can also be done without a stack if the nodes have parent
references, and then it is similar to backtracking
Heaps
a heap is a binary tree (but not a binary search tree)
in which each node has a value less than its children (min heap)
or a value greater than its children (max heap)
this is the heap property
so nodes in a heap are not sorted
heap requirements
as well as the heap property of each node needing to be less (greater)
than its children,
in a heap, all leaves at
maximum depth dmax are to the left of all the other
leaves, which are at depth dmax - 1
in-class exercise: is this a max or a min heap?
such a binary tree (all leaves at max depth to the left of
all other leaves, which are at depth dmax - 1)
is called a complete binary tree
a heap is always a complete binary tree
a complete binary tree is always balanced, so that
a complete binary tree of n nodes has depth O(log n)
in-class exercise: in what sense can I say that a complete binary
tree is balanced?
heap storage
any complete binary tree, including any heap,
can be conveniently stored in an array:
element 0 of the array stores the root
elements 1 and 2 of the array store the nodes at depth 1
elements 3, 4, 5, and 6 of the array store the nodes at depth 2
nodes at depth d are stored in array elements
2d-1...2d+1 - 2
conveniently, there is no need to store any pointers: a
node stored in array element i has:
its parent in array element (i - 1) / 2
its left child (if any) in array element 2i + 1
its right child (if any) in array element 2i + 2
since a heap is a complete binary tree, the right child
can only be present if the left child is also present (there
may be one left child leaf node that does not have a right sibling)
in-class exercises
store this heap into an array
which of the following arrays store max heaps, min heaps, or neither?
the two heap requirements must be maintained when adding
to a heap
to maintain the complete binary tree property, the new
node must be added to the right of all nodes at depth
dmax
or, if there already are 2(dmax) nodes
at that level, the new node should be inserted all the way to the
left, making the tree deeper by one level
either way, the new value is inserted in the array just after
all elements already in the array
now the tree is complete, but may not have the heap property
to check, compare the node with the parent, and swap the two
if needed to maintain the heap property
continue with the parent's parent, all the way to the root if
necessary
now the complete binary tree also obeys the heap property
Max heap deletion
the largest node is at the root of the heap
that node is deleted, and replaced with the bottommost, rightmost node
the remaining tree is complete, but may not have the tree property
if the root node is less than either of its children, it is
swapped with the largest of its children
the operation continues with the new node
now the complete binary tree also obeys the heap property
similarly for min heaps
in-class exercises
insert into a heap the following values:
1 9 77 14 3 55 66 7 8
remove from the heap each of the elements in turn
priority queues
the queues studied so far were strictly FIFO
that means objects were returned in the order inserted
in the real world, often have priorities, e.g.:
at airport check-in, there is a special line for first-class
passengers
if any first-class passengers are waiting, they are handled first
only if no first-class passengers are waiting, only then the other
passengers can check-in
likewise in the emergency room at a hospital or after a disaster
the process of determining which patients should be seen first
is called triage (a medical term, not a computer science term)
priority queue implementations
linked list: objects are inserted in the proper place in the
list (linear time), objects are returned from the front of the list
(constant time)
array: objects are inserted in the proper place in the
array, with all other objects shifted to make room (linear time),
objects are returned from the front of the array, with all other
objects shifted down (linear time), or maintained as a circular
array (constant time)
binary search tree: objects are inserted into the binary search
tree, using the priority as the key (log or linear), objects are removed
from the rightmost node of the tree (log or linear)
heap: objects are inserted into the heap using the priority as the
key (log time), and removed from the top of the heap (log time)